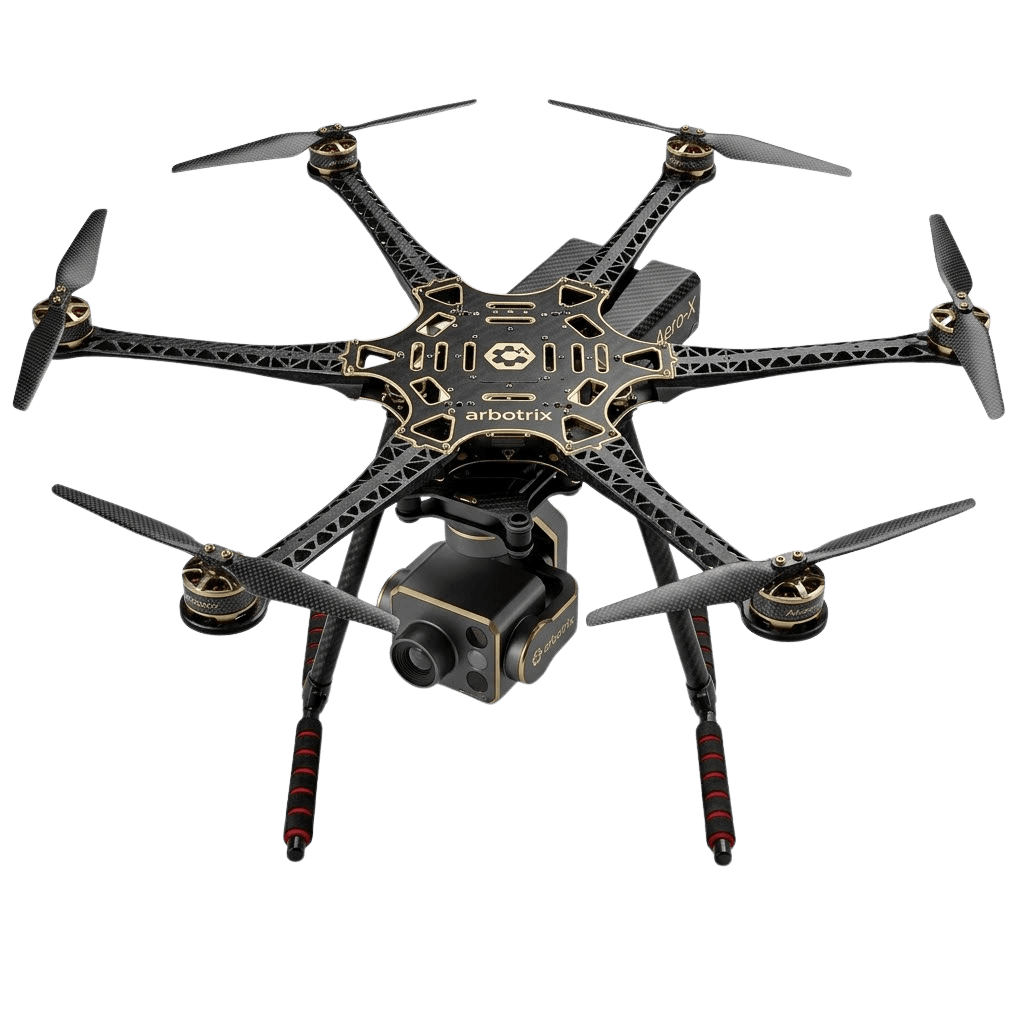
Aero-X
UAV System
Dominate The Airspace.
Bypass ground obstacles with real-time spatial awareness. The Aero-X integrates lightweight edge computing with precision flight hardware to execute automated perimeter mapping and continuous object tracking.
Pixhawk
Flight Controller
SITL
Digital Twin Sim
Telemetry
Mission Planner
ROS2
Autonomous Nodes
Zero-Risk Deployment
Physical testing without software verification is a liability. Our flight architecture mandates rigorous virtual simulation and telemetry tuning before the drone ever spins a rotor.
[INIT] Starting ArduPilot Software-In-The-Loop...
sim_vehicle.py -v ArduCopter -f quad --console --map
[MAVLink] Connecting to tcp:127.0.0.1:5760
[SYS] Pixhawk Firmware Version: 4.4.1
[PARAM] Loading default quadcopter parameters...
[PARAM] BATT_MONITOR = 4
[PARAM] ARMING_CHECK = 1
[CALIBRATION] Verifying motor channel outputs 1-4... OK.
[GPS] EKF3 IMU0 is using GPS. 3D Fix acquired.
[STATUS] Ready to arm. Switching to GUIDED mode.
SITL Digital Twin Testing
We eliminate firmware anomalies by running ArduPilot Software-In-The-Loop (SITL) simulations. This allows us to inject virtual GPS data and validate ROS2 trajectory nodes in a risk-free environment.
Hardware Calibration & Failsafes
Integration relies on perfect calibration. Through Mission Planner, we execute precise channel configuration and Pixhawk motor testing, guaranteeing the flight controller will reject takeoff if voltage drops or GPS lock is lost.
Live Telemetry & ROS2
By bridging the MAVLink protocol with custom ROS2 nodes, we parse live telemetry data to execute dynamic, autonomous perimeter sweeps without manual pilot intervention.
Secure Your Airspace.
Stop relying on commercial drones with closed ecosystems. Integrate an autonomous aerial platform built for enterprise telemetry and custom payloads.
Consult Engineering Team